
01 Intended use
Fixed route floor scrubber
For repeated cleaning in public areas of buildings, integrate water replenishment, drainage, and patrol into the same task.

The Jinjie J-W70 is an autonomous scrubber for repeated commercial hard-floor routes, with 510 mm cleaning coverage and 70 L/55 L tanks. Replenishment depends on configuration; people remain responsible for checks, exceptions and takeover.
Fixed route floor scrubber
For repeated cleaning in public areas of buildings, integrate water replenishment, drainage, and patrol into the same task.
Washing and wastewater recovery
510 mm clear width, fresh water tank 70 L, dirty water tank 55 L; ground effect is checked according to actual route.
Supply according to version selection.
Charging arrangements listed include manual charging, a charging dock and a workstation. Confirm workstation integration and optional equipment separately.
View the website playback version for operation reference, while assessing selection against the actual task and conditions.
The video helps explain appearance and operation; it does not replace site verification.
Watch J-W70 operation at a site and review how it fits your working conditions.
Large water tanks and multiple refilling methods, arranging unmanned floor scrubbing around long routes
The replenishment of fresh water, wastewater treatment, and the return route to the station will affect the overall task schedule.
Access control, elevator, network, and parking locations need to be confirmed item by item, not just based on the navigation name.
Floor surface, dirt, and water absorption state need to be checked on the actual route, not just based on the image's reflection.
First, verify the path, thresholds, personnel crossings, and temporary obstacles along the real route. Then confirm the map, return station, supplies, and manual takeover. J-W70 The data work time for floor scrubbing and dust mopping should be understood separately and not calculated as the same cleaning mode. Daily maintenance of the water tank, brushes, rubber seals, and sensor areas is still required after deployment.
Floor material, continuous route, and corner.
Changes in pedestrian flow, business hours, and residual water.
Clear width at the door, charging, and manual takeover.
Water supply, drainage, power supply, and compatibility conditions
| Field or task | Configuration and operating conditions to check | J-W70 Selection Judgment |
|---|---|---|
| Long corridor in the building | Floor material, continuous route, and corner. | Plan the cleaning route together with the supply points, without directly committing to the working area based on the water tank capacity. |
| Public areas of the hotel | Changes in pedestrian flow, business hours, and residual water. | First, verify the cleaning and recovery performance during the agreed time frame. Temporary obstacles will be handled by personnel. |
| Office floor | Clear width at the door, charging, and manual takeover. | First confirm the operating area of this floor. The lift control is a separate optional feature and must be verified against the project. |
| Workstation installation | Water supply, drainage, power supply, and compatibility conditions | The work station and automatic supply are not standard features of all versions; the delivery scope should be confirmed item by item. |
Prepare a floor plan or road photo, the floor material and contaminants, the narrowest passage and corners, and the traffic and vehicle activity periods. Then verify the charging, waste collection, or water replenishment points, as well as the responsible person for abnormal hose connections.
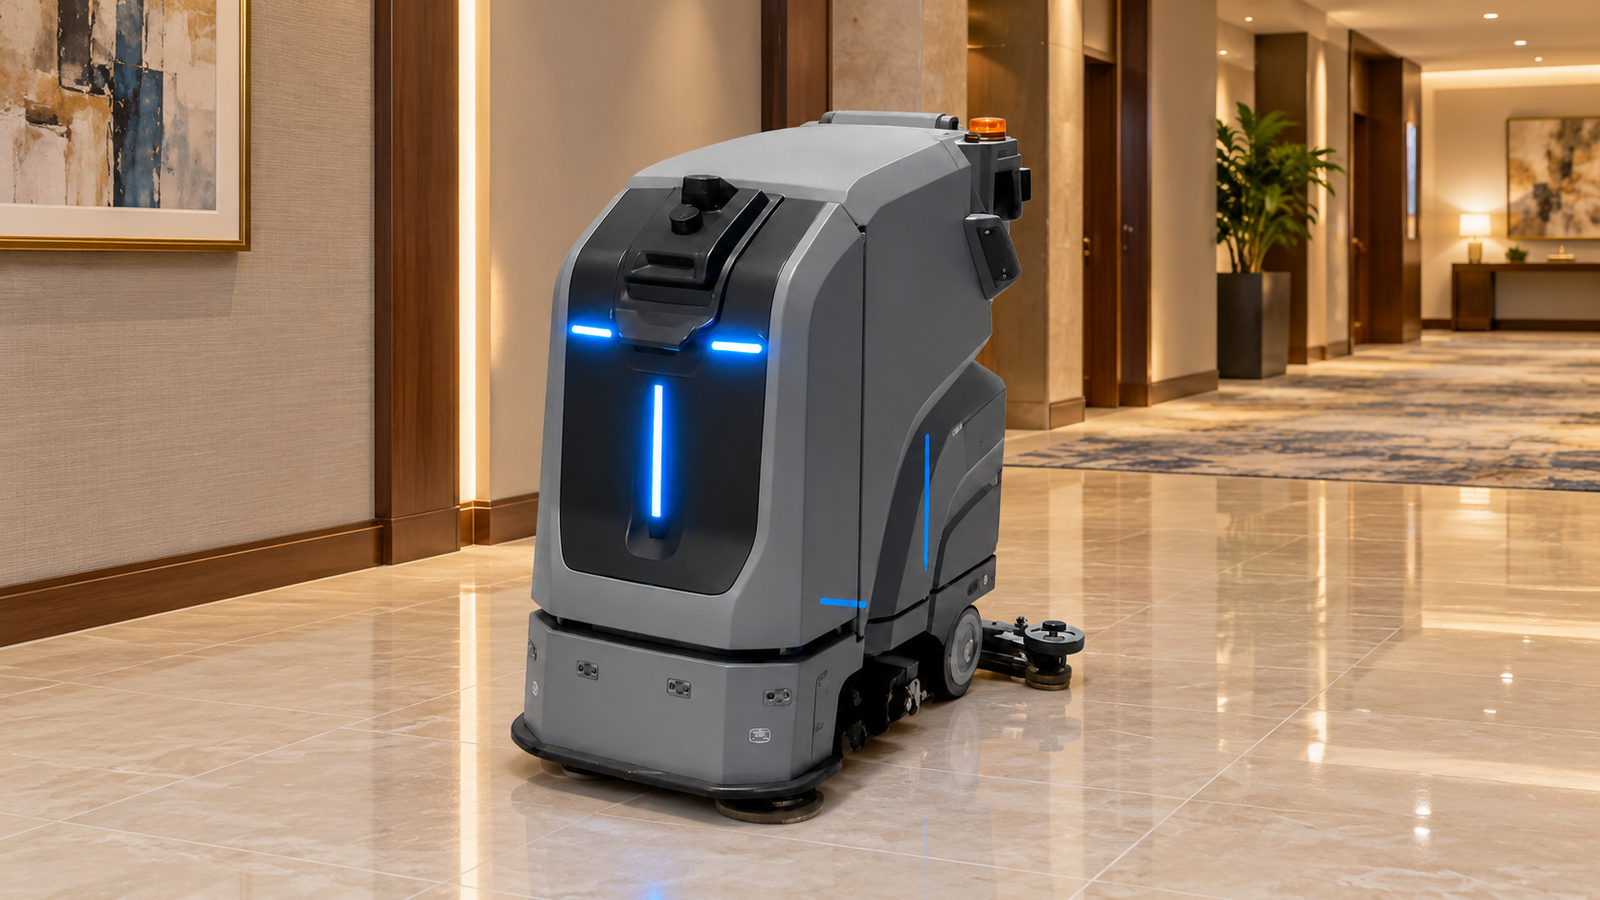 J-W70 · AI application illustration
Plan repeated routes on level lobby floors, dividing zones around guest movement.
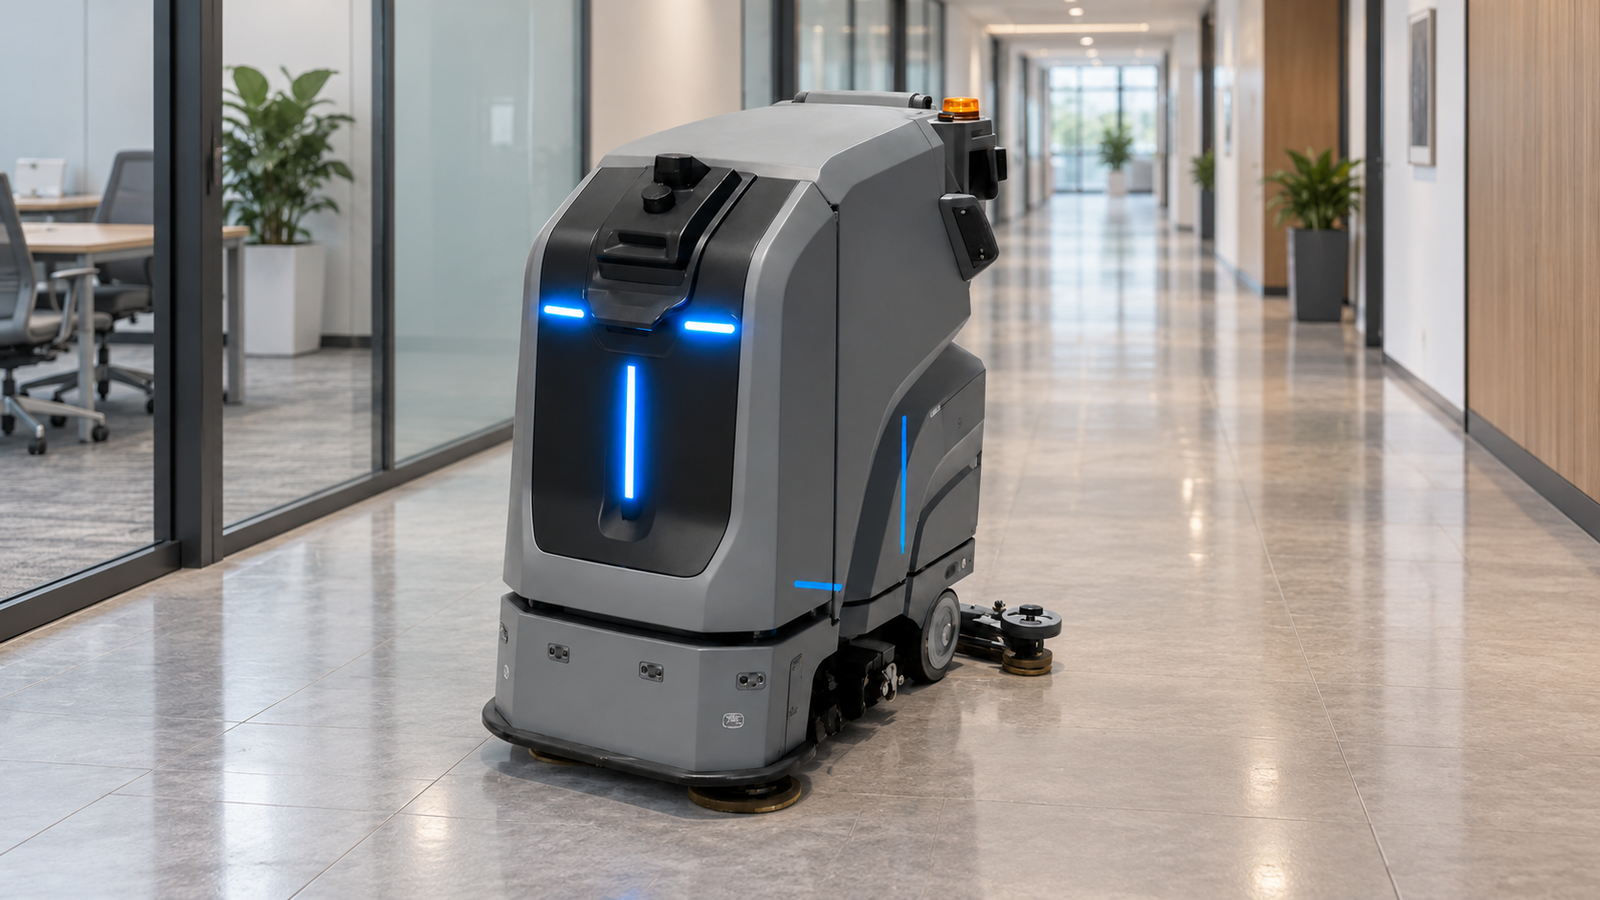 J-W70 · AI application illustration
Plan routine floor care along public passages after checking doorways, obstacles and replenishment points.
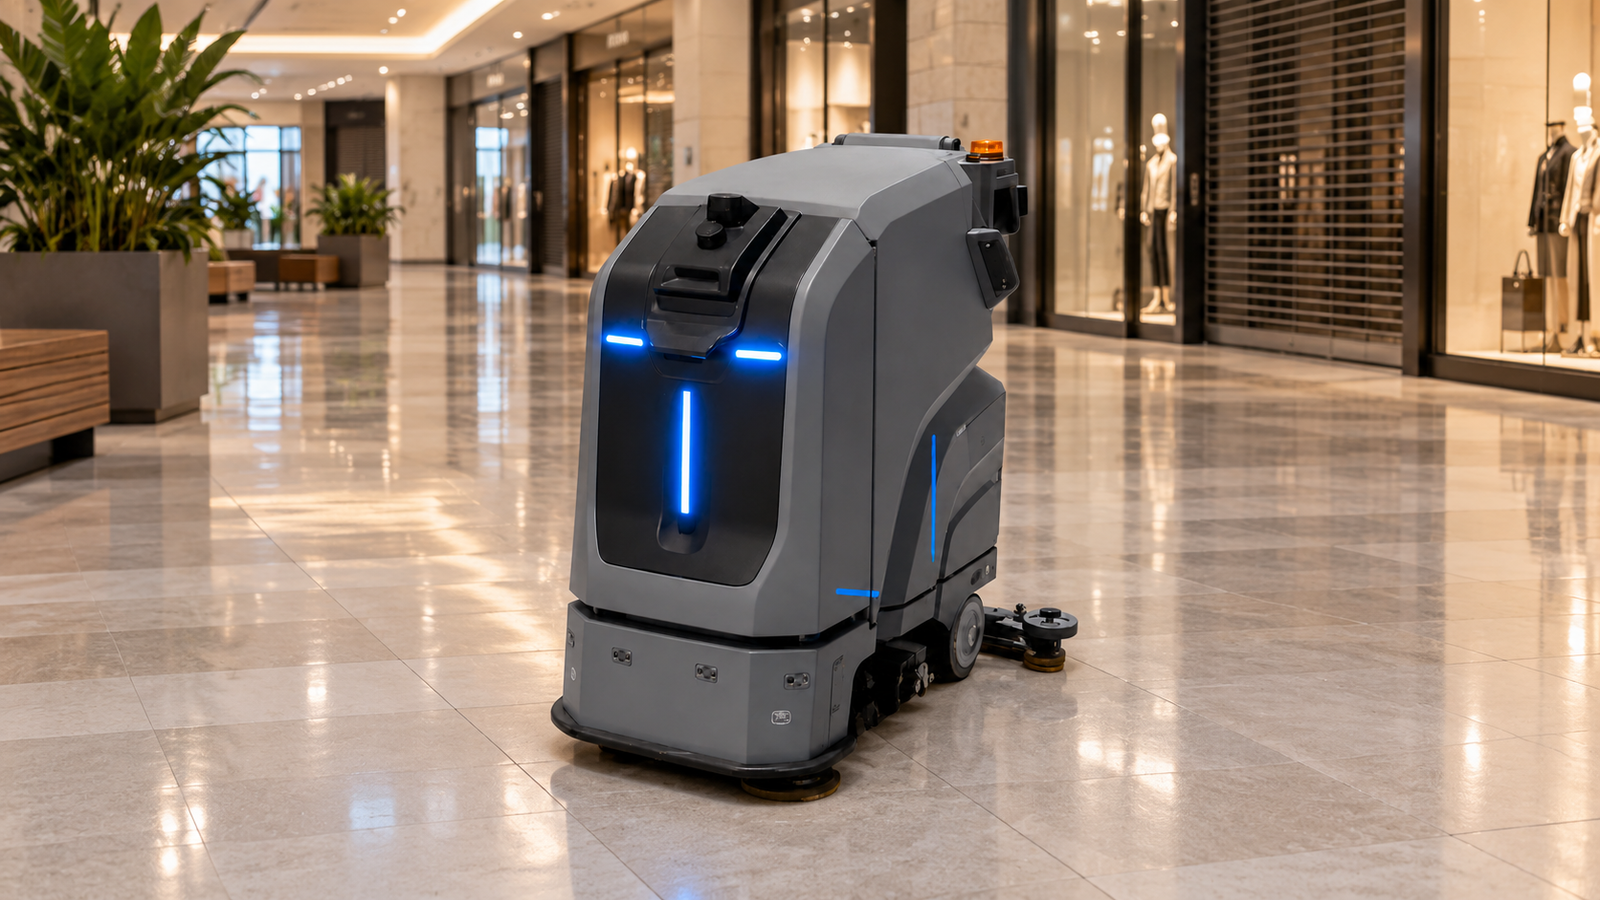 J-W70 · AI application illustration
Maintain commercial passages at quieter times, confirming moving obstacles and operator takeover on site.
First, check the settings related to daily use. The complete specifications can be viewed in detail.
| Key operating figures | |||
|---|---|---|---|
| Cleaning width | 510mm | Squeegee width | 810mm |
| Clean water tank | 70L | sewage tank | 55L |
| Runtime reference | Approximately 3h scrubbing / 10h dust mopping | Cleaning modes | Scrub and recover, scrub only, recovery only, dust mop; optional disinfection module |
| Maximum operating speed | 1.4m/s | Brush pressure against the floor | 27kg |
| Operating temperature | 0℃~40℃ | Body filler edge distance | About 15 cm |
| Manual operation | Supports operator takeover and manual operation | Function extensions | Travel recording and remote upgrades listed as standard; lift control and disinfection optional |
| Drive and electrical system | |||
| Operating voltage | 24V | Charging method | Manual charging / automatic charging dock / intelligent workstation |
| Machine configuration | |||
| Travel mode | Autonomous travel, automatic return for charging and operator takeover | Machine dimensions | 1160×580×1210mm |
| Machine weight | 199kg, excluding water | Product model | J-W70 |
| Navigation method | Fused vision and LiDAR navigation | Operating noise | 65~75dB |
| Perception system | Panoramic camera, 270° LiDAR, 360° depth camera, 360° ultrasonic sensors, IMU and electronic bumper strip; 3D LiDAR optional | ||
The data on battery life, operating speed, mode efficiency, and actual task completion should be understood separately. The routes, supply, waste removal, and manual finishing are all counted as actual tasks.
Theoretical efficiency, documentation working time, and actual continuous operation performance should be understood separately. On-site conditions and final delivery configuration need to be verified together.
Use the complete machine diagram for the corresponding model; the following numbers are function description indices, and unverified internal component locations are not marked

Clear water 70 L and dirty water 55 L should be managed separately, and the replenishment and discharge of water should be combined with the route arrangement.
510 mm cleaning width, the brush and cleaning mode are selected according to the floor material and dirt type.
810 mm squeegee combined with recovery, check the rubber strip, seal, and piping condition.
The visual and laser fusion navigation system is in the process of deployment, with the operational area and boundaries completed.
Manual charging, charging stations, or workstations should be selected according to the actual version, and they are not defaultfully equipped with all features.
Operators can take over manually. Assign staff to clear temporary obstructions, empty the hopper and deal with faults.
The following is a task flow description, which does not replace internal mechanical diagrams or specific operation manuals; it is executed according to the machine's delivered training.
Combine commercial floor areas with task zones, no-entry boundaries, and water replenishment and drainage locations.
Arrange floor scrubbing, only scrubbing, only suction, or dust pushing according to the actual delivery mode, and separately verify the floor surface.
Execute tasks along the deployment route, check for brush residue and water recovery, do not use empty field demonstrations as a substitute for acceptance.
Finish according to the selected charging and replenishment method, with personnel handling the housing, consumables, and unfinished areas.
Water supply, drainage, power supply, network, and site compatibility are respectively confirmed. Automatic water supply and drainage are not inferred from the workstation name.
The data lists step ladder control, pest control, and 3D laser radar as optional directions. Delivery will be determined based on the machine version and list.
Approximately 3 hours of scrubbing and 10 hours of dry mopping are figures for separate modes. Apply each only to its stated duty.
The reference machine separately demonstrates task combinations, water tanks, and refilling methods. First, determine what needs to be solved on-site, then compare the configurations.
| Comparison criteria |  AllyBot-C2 | J-W70 |  CC1 |
|---|---|---|---|
| Work direction | Indoor floor scrubbing, dusting, and dust mop | Fixed route unmanned floor scrubber | Sweeping, scrubbing, vacuuming and dust mopping |
| Clean or sweep area | 440mm | 510mm | Floor scrubber clearance: 400 mm; Sweeper clearance: 500 mm. |
| Water tank or waste collection | Clear water 10 L / dirty water 10 L | Clear water 70 L / dirty water 55 L | Clear water about 15 L / dirty water about 17 L; garbage about 6 L; |
| Navigation or control | Autonomous navigation, supports manual takeover | Fused vision and LiDAR navigation | Visual SLAM + LiDAR SLAM |
| Supplemental supply and personnel arrangement. | Automatic hose retraction; the housing is managed by personnel. | Charge/workstation select by version | Automatic hose retraction; drainage required with workstation. |
| Selection focus | Compact body with zone-based tasks. | Long line and supply arrangement. | Multi-mode and consumable switching schedule |
Check the machine, charging point, network and accessories required on site. List any workstation separately to avoid counting it twice.
Include filling, draining, return to station, inspection and charging in the shift plan for a long route.
Record consumables, maintenance, and energy usage based on the actual brush, collection, or recovery configuration of the machine; no fixed person-saving ratio is committed without data of the same diameter.
Follow the machine instructions for water replenishment, drainage, and body cleaning, and check the seal and odors.
Check the brush or dust mop consumables according to the actual task, noting wear and entanglement.
Check for visible rubber seals, sealing, and recovery pathways; water residue issues should be verified in conjunction with the floor surface.
Follow the machine's instructions to clean the visible perception window; do not arbitrarily block, move, or disassemble the sensor.
Check the battery charging and actual supply configuration of the machine, and maintain the workstation according to its instructions.
Retain the unfinished areas, blocked positions, and prompt information. Abnormalities are to be taken over according to training and contact after-sales.
Service scope, costs, and on-site arrangements are confirmed based on the actual project and agreement.
Check together the machine version, configuration, random documents, and accompanying conditions.
Understand the operation by combining the machine's task mode, deployment boundary, maintenance, and manual takeover.
Bring the model number, route conditions, and equipment prompts for communication of tasks and usage issues.
Check the actual consumables, replaceable parts, and compatible configurations against the machine version.
Service scope, fees, and arrival arrangements should be confirmed in advance, and will be executed according to the actual agreement.
Combine usage frequency, location, and actual agreed maintenance arrangements.
Assess suitable fixed-route scrubbing and dust-mopping tasks, such as repetitive commercial aisle cleaning. Define routes, pedestrian periods, supply stops and takeover staff. Record inspection, care, edge finishing and cleaning results before assigning work.
Check 510 mm scrubbing coverage and the 810 mm squeegee separately, then assess the complete envelope, turns, thresholds and changing obstacles. Trial cleaning coverage and avoidance on the deployment route; cleaning width alone does not establish passage or task completion.
The supply method and accompanying facilities should be confirmed according to the delivered version. The return to station, sewage discharge, and cleaning should be included in the tasks. It is necessary to arrange based on the mode, water supply, dirt, and recovery conditions, and it cannot be assumed that the entire route does not require sewage discharge simply because the clear water tank is large.
First distinguish scrubbing from dust mopping: the listed references are approximately 3 and 10 hours respectively, with different loads and water use. Record charging, supplies and manual interventions separately before scheduling; dust-mopping duration is not continuous scrubbing time.
Validate permitted conditions, exception handling and takeover before deployment. People still manage the site. Sensing or navigation is not a promise of intervention-free work in every dynamic environment; use delivered instructions and trial records.
First distinguish long-route washing from multi-mode zoned work. Compare tanks, replenishment, mode changes and finishing. Evaluate the same task and acceptance method rather than just function counts or runtime.
In addition to brushes, squeegee, tanks and hoses, check sensing and return conditions as instructed, and verify task operation after maintenance. Stop safely and take over when abnormal; do not modify control or navigation assemblies without authorization.
Provide information on the floor material, waste type, route, floor connection, peak traffic times, network, and supply conditions, and specify the on-duty personnel arrangement. Wanshenglong will communicate the equipment configuration and trial operation based on this. The delivery training and service scope will be confirmed according to the actual project.
Discuss the floor, routes, and daily cleaning schedule, and together see if J-W70 is suitable.
Phone consultation: 0755-25621811 View other contact information →
Product enquiryBring a route plan, photographs of the floor or debris, and details of pedestrian and vehicle movements. Identify refill points, network coverage and who will inspect the machine or take over. We can then assess which tasks suit the configuration.